
Since 2024, as automakers accelerate their entry and capital floods in, the humanoid robot industry has entered its inaugural year of explosive growth. However, as the industry transitions from enthusiastic "lab demonstrations" to the rigorous "scaled commercialization," we are facing a critical leap from Level 2 to Level 3 (from demonstration to stable task delivery).
At the recently held "VeriSilicon Embodied Robot Special Technical Seminar", experts from UBTECH, Digua Robotics, VeriSilicon, Shanghai SDIC Fund, and Yole Group engaged in intense discussions reg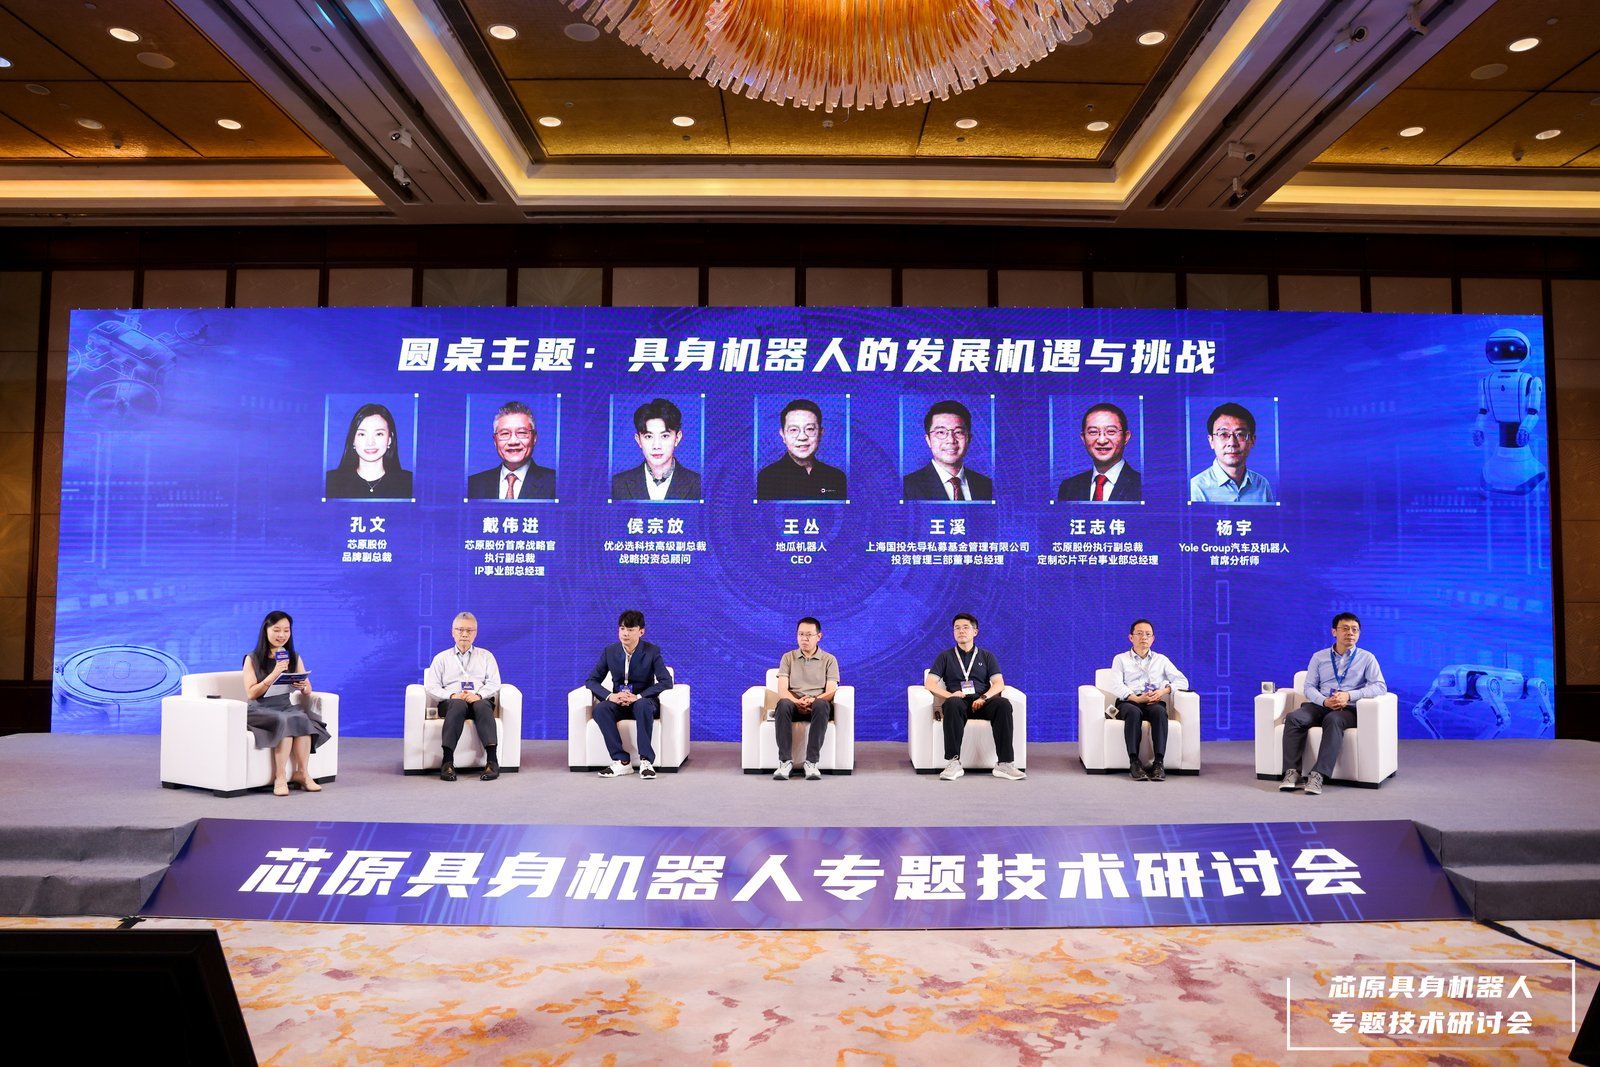
When Will the "Tipping Point" for Scaled Commercialization Arrive? Regarding when the industry can achieve the leap from "10,000 to 100,000 units," two representative voices have emerged within the industry: Optimists (Industry Pioneers): Hou Zongfang, Senior Vice President and Chief Strategic Investment Advisor at UBTECH, pointed out that the demand from consumers and B-end users far exceeds the industry's output. He boldly predicted that the shipment volume of a single model has the opportunity to exceed 100,000 units within two years, and the ultimate key to breaking the deadlock lies in the birth of a general-purpose "Foundation Model". Pragmatists (Chip and Analysis Firms): Wang Cong, CEO of Digua Robotics, and Yang Yu, Chief Analyst for Automotive and Robotics at Yole Group, believe that the possibility of generalization in the to-C market is not visible in the short term. In the absence of a general large model, they can only rely on Specific Tasks to tackle scenarios one by one. For a single model to exceed 100,000 units, a conservative estimate requires three to five years.
Core Obstacles: The fundamental bottleneck for the industry to break through lies not in insufficient demand, but in the fact that general foundation models are not yet ready and data collection standards are unclear, resulting in robots lacking generalization capabilities in non-specific scenarios.
The Technical Game Between the Brain and Cerebellum: Discrete or Integrated? The technical architecture of humanoid robots is divided into the brain (cognitive decision-making) and the cerebellum (motion control). Faced with these two vastly different computing power requirements, chip design faces a route choice: Firm Discretion: Technical Isolation Based on Safety and Real-Time Performance Wang Zhiwei, Executive Vice President of VeriSilicon, pointed out that the brain is responsible for complex environment analysis and planning, which inherently lacks high real-time performance; the cerebellum, on the other hand, requires low latency and high reliability. He believes that the brain and cerebellum must be isolated physically or logically. Even if the AI system of the brain fails, the cerebellum responsible for motion control must never crash, otherwise it will cause fatal failures. In addition, humanoid robots may have one brain and multiple cerebellums responsible for different joints and tactile perception in the future, making hard integration unrealistic. Collaborative Computing: The Cerebellum "Unburdens" the Brain Dai Weijin, Chief Strategy Officer of VeriSilicon, proposed an optimization path: utilizing the cerebellum to perform advance simplification and lightweight processing of data at the edge side and sensor front-end, and then transmitting it to the brain. This can avoid overwhelming the bandwidth and computing power of the main SoC (System on Chip) with massive amounts of raw multimodal data, optimizing overall cost-effectiveness. Pragmatic Phased Theory: Integrating the Brain and Cerebellum is a Pseudo-Problem at This Stage Wang Cong, CEO of Digua Robotics, frankly stated that, given that foundation models and algorithms are not yet finalized, the most urgent task at present is to figure out the financial viability, using the MCU (Microcontroller Unit) to save resources for the CPU, and first solving the practical problems of "whether it can move and whether it can perform tasks".
Automakers Enter the Fray: What Are the Compelling Advantages and Essential Differences of Technology Reuse? In 2024, automakers became the most conspicuous "barbarians" in the humanoid robot track, successively laying out through independent research, investment, or cooperative development. This is because automakers have three natural advantages when entering the robot track: Shared Supply Chain: The existing supply chains of automakers for motors, sensors, power batteries, etc., can be quickly reused. Shared Decision-Making Layer: The AI decision-making chips for intelligent driving and robot chips share technological homology. Shared Scenarios: Automobile manufacturing plants themselves are the most perfect testing grounds for the unmanned deployment of humanoid robots. However, there is a fundamental boundary between automobiles and humanoid robots. Wang Zhiwei, Executive Vice President of VeriSilicon, pointed out that automobiles belong to "fixed scenarios"—they have high-definition maps and fixed driving routes. But humanoid robots face "unknown scenarios" (especially when entering homes). Robots must go anywhere and rebuild maps in real time. This extreme requirement for instant environmental perception and generalized reasoning means that the computing power of existing edge-side chips (even if reaching 500 TOPS to 800 TOPS) is still far from sufficient.
Summary and Outlook In 2025, the global shipment volume of humanoid robots is approximately 13,000 to 18,000 units, of which China accounts for more than 80% of the share, leading the world. Integrating the views of various experts at this forum, from the perspective of investment and industrial ecosystem construction, the future strategic focus will concentrate on the following three points: Dual-Wheel Drive of Algorithms and Data: Accelerate large-scale data collection and scenario library construction, and explore a rolling closed-loop foundation model training path. Priority Optimization of Chip Metrics: The chip side should prioritize optimizing peak computing power, energy efficiency ratio, and low-latency real-time processing capabilities to adapt to complex edge-side real-time dynamic mapping. Cross-Boundary Ecosystem Integration: Bridging the gap from Level 2 to Level 3 requires deep collaboration among chip manufacturers, complete machine manufacturers, and automotive supply chains to translate technical metrics into commercially viable tasks that can be stably delivered.
In short, humanoid robots are not a simple extension of intelligent vehicles; they are the ultimate form of embodied intelligence. When the foundation model crosses the inflection point, the moment of industrial breakthrough of 100,000 units will come more fiercely than imagined.